Shafeef Omar
PhD Student @ Applied and Theoretical Aspects of Robot Intelligence (ATARI) Lab. Munich Institute of Robotics and Machine Intelligence (MIRMI). Technical University of Munich (TUM).

I am a PhD student with ATARI Lab, supervised by Prof. Majid Khadiv and co-supervised by Prof. Cordelia Schmid.
Previously, I was a research fellow with the Dynamic Legged Systems (DLS) Group, headed by Claudio Semini at the Istituto Italiano di Tecnologia, where I worked on quadrupeds for safe vision-aided locomotion. Before that, I was a Research Associate at the Indian Institute of Science, where I worked on Continual Learning for mitigating catastrophic forgetting in neural networks at the Artificial Intelligence and Robotics Laboratory. I graduated from the Indian Institute of Technology Madras (IIT-M) with an Engineering Dual Degree, Bachelor and Master of Technology.
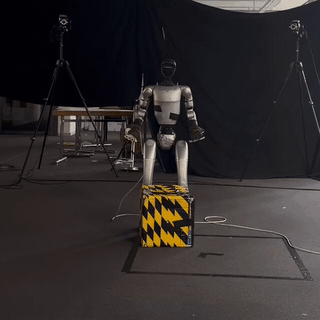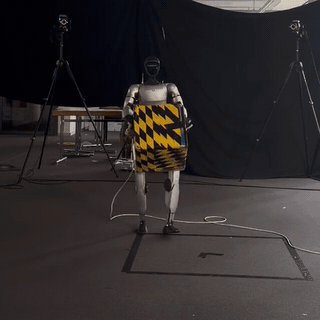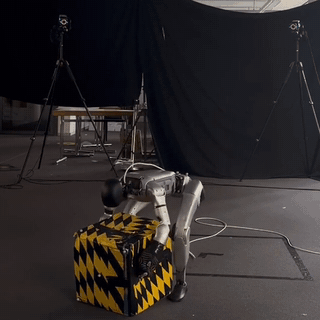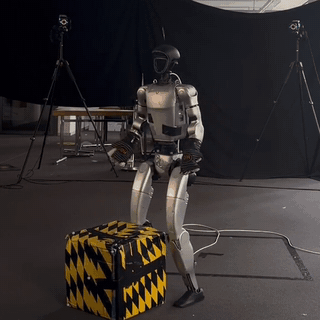
My research focuses on generalizable robot learning, especially humanoid loco-manipulation: coordinating locomotion, balance, and interaction with objects. I combine reinforcement learning, trajectory optimization, and diffusion models to learn diverse behaviors from limited demonstrations and autonomous motion discovery. I am also interested in motion retargeting, safe adaptation on hardware, and vision-language-action models (VLAs).
Recent work includes DiPLO, which combines a self-distilled diffusion planner with a whole-body tracker; MotionDisco, which discovers humanoid skills without demonstrations; and DynaRetarget, which turns human motions into dynamically feasible robot trajectories. See Google Scholar for my full publication list.
Work with us : I am currently seeking exceptional master’s students interested in contributing to our research in reinforcement learning for robotics. If you are enthusiastic about developing advanced algorithms and applying them to real-world legged robots, please feel free to get in touch!
news
| Oct 17, 2026 | New preprint: DiPLO combines self-distilled diffusion planning with whole-body tracking for humanoid loco-manipulation, with deployment on a real Unitree G1. [paper] [website] [video] |
|---|---|
| Oct 15, 2026 | DynaRetarget and Humanoid-DART have been accepted to IEEE Robotics and Automation Letters (RA-L)! [DynaRetarget paper] [Humanoid-DART paper] |
| Jul 28, 2026 | Our work FARO received the Best Poster Award at the IEEE RAS Technical Committee on Optimization for Robotics virtual poster session and networking event. [event] [paper] |
| Jul 20, 2026 | New preprint: FARO uses feasibility-aware motion optimization to search for and execute humanoid loco-manipulation behaviors. [paper] [video] |
| Jun 25, 2026 | New preprint: Humanoid-DART combines diffusion-based trajectory generation and reinforcement learning to expand humanoid loco-manipulation skills from sparse demonstrations. [paper] |
| Jun 17, 2026 | Learning to Act Through Contact is published in the proceedings of L4DC 2026, PMLR volume 331. [proceedings] [video] |
| Jun 7, 2026 | New preprint: MotionDisco: Motion Discovery for Extreme Humanoid Loco-Manipulation is now available on arXiv. [paper] [website] [video] |
| Mar 17, 2026 | New preprint: SLowRL combines low-rank adaptation with a recovery policy for safer, more efficient fine-tuning of locomotion policies on hardware. [paper] |
| Feb 10, 2026 | New preprint: DynaRetarget: Dynamically-Feasible Retargeting using Sampling-Based Trajectory Optimization is now available on arXiv. [paper] [website] [video] |
| Oct 6, 2025 | New preprint: Learning to Act Through Contact: A Unified View of Multi-Task Robot Learning is now available on arXiv. [paper] [video] |
| Jul 12, 2024 | Presented our recent work on Learning to Climb Vertical Ladders with Quadrupeds using Carpal-Claw Design at the TC Poster Session and Networking Event 2024 [presentation] [video]. |
| Apr 15, 2024 | I have officially started my PhD with the ATARI Lab at the Technical University of Munich. |
| Sep 30, 2023 | SafeSteps has been accepted to the IEEE-RAS International Conference on Humanoid Robots 2023. |
| Jul 24, 2023 | The preprint of our latest paper on Safe Foothold Adaptations for Legged Robots, SafeSteps, is now available. See the publications section. |
| May 22, 2022 | Joined the Dynamic Legged Systems Lab (DLS@IIT). |